World models & VLA
event_type · action · tools
Structured failure-and-recovery episodes are available to robotics teams under NDA request access →
Robots learn the task from demonstrations. They learn recovery from nothing. We capture the part everyone throws away.
Task-demonstration datasets record the clean run and stop. Four things happen in real industrial work that they have no representation for at all.
01 / 04 · failure
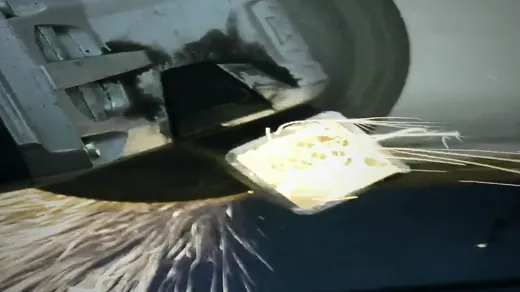 failure
The moment the job stops going to plan, with the seconds either side of it. A rounded bolt head, a dropped bead, a jam that returns four cartons later.
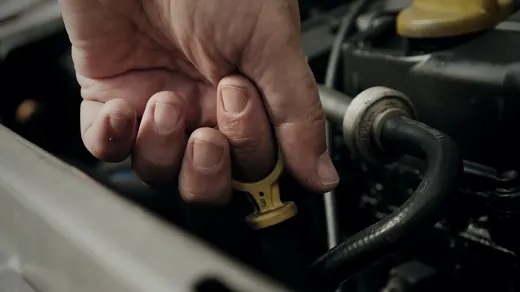 diagnosis
What the technician checks, in what order, and what they rule out. This is the expensive part of the expertise and the part no procedure document contains.
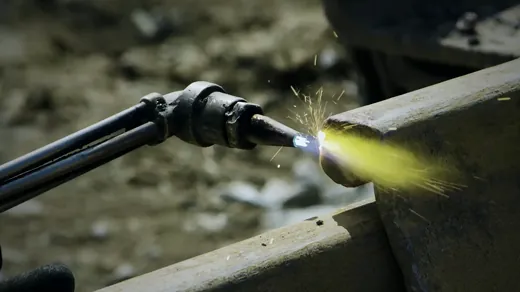 intervention
The off-procedure work. Tool changes, improvised fixtures, heat, force, patience. Often the longest stretch of the episode and always the least documented.
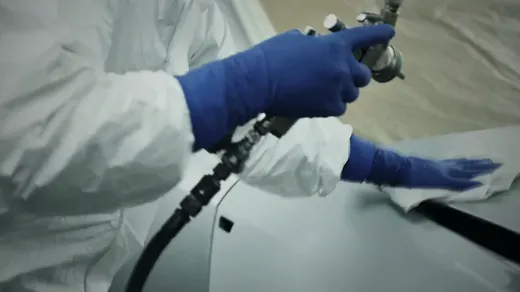 recovery
Getting back to the procedure, not just getting it working. A model trained only on clean runs has no policy for the return path.
event_type · action · tools
repeated_attempt · attempts · failed_attempts
symptoms · root_cause_provenance · confidence.causal
off_nominal · evidence_count · grounded
for robotics and physical AI
A full episode with video, labelled timeline and structured record, plus the schema. Enough to judge whether recovery data changes your policy.
for industrial operators
We fit capture around work that is already happening. Your technicians keep working; the expertise stops leaving when they do.